Mechanisms before code
Tendon path length and joint friction show up in your hands before you touch the IDE. Optional microcontroller extras are secondary to the kinematics.
Projects / Animatronic Hand
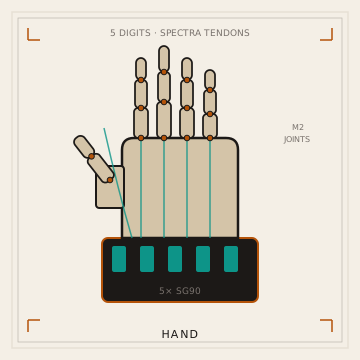
Flagship pack — a complete animatronics apprenticeship in one build. Laser-cut 3mm birch plywood, M2/M3 revolute joints, Spectra tendons, five SG90s, wiring, PWM, and calibration. Finish with a keepable desk / club machine, not a throwaway craft.
Homeschool / co-op leaders: buy the $39 Homeschool / Co-op pack (includes facilitator addendum). Individual makers use $12. Free sample first if you want a look.
Digital files only (guide + cut files + BOM + code). Plywood + servos sourced separately · Ages 8–14 with adult help · Instant unlock after Stripe
Marketing matches the build: laser-cut birch plywood, machine-screw hinges, Spectra tendons, and five SG90 micro servos—hobby electronics you can source, not a factory robot arm.
The $12 pack is the digital guide + cut files + BOM + lessons + code, plus printable Builder's Corner build journal pages. Hardware is sourced separately — see Where to get kit materials. Buy with Stripe is live below.
Questions? Email us at lance.haney@gmail.com.
Tendon path length and joint friction show up in your hands before you touch the IDE. Optional microcontroller extras are secondary to the kinematics.
Five SG90s, M2/M3 revolute joints, Spectra tendons, birch plywood (or PETG), Arduino Uno. Common hobby parts—no proprietary lock-in. Sourcing guide →
Finish the base five-digit hand, then add antagonist extensors, joint sensors, or a mirrored second hand. The pack ends where your experiments begin.