Projects / Pneumatic Soft Gripper
Pneumatic Soft Gripper
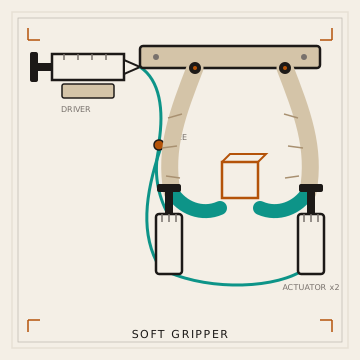
Build a syringe-driven pneumatic gripper: press a driver syringe to transmit pressure through tubing to actuator syringes (or an optional silicone/nitrile bladder, never a balloon) that close soft fingertips. Mount on laser-cut 3mm birch. Optional silicone tips; optional servo motorization.
Digital guide + cut files + BOM + code · Parts sourced separately · Ages 8–14 with adult help
Pack contents
- Birch gripper mount SVG
- Build guide: mount, plumb, optional motorize
- First-principles: Pascal, force, soft robotics
- Optional servo-depress firmware
- Verified BOM (~$14–48 hardware)
Typical hardware cost
Default structure is laser-cut birch plywood with real fasteners and hobby electronics you can source—honest BOM, not mystery modules.
- ~$14–48 in typical parts (makerspace cut toward the low end; mail-order toward the high end)
- Digital pack price ≠ hardware
The $9 pack is the digital guide + cut files + BOM + lessons + code, plus printable Builder's Corner build journal pages. Hardware is sourced separately — see Where to get kit materials. Buy with Stripe is live below.
Questions? Email us at lance.haney@gmail.com.
Pricing
- Home / Personal license $9
- Classroom license $35 — 1 teacher, up to 30 studentsOne $35 Classroom license covers one group of up to 30 students. Each additional group needs another license.
- Build materials available at cost + 10% — email for a quote
Learning outcomes
- State Pascal’s principle and predict force from pressure × area
- Build a closed air volume with minimal leaks
- Compare rigid vs soft fingertip grasp
- Optional: PWM a servo to depress the driver syringe